Robotic Gripper Attachment
During my internship at Contactile, I designed a device to control and power a robotic gripper. The purpose of this device was to enable mobile demonstration of the gipper at academic conferences.
I designed this 4-layer PCB in KiCad:
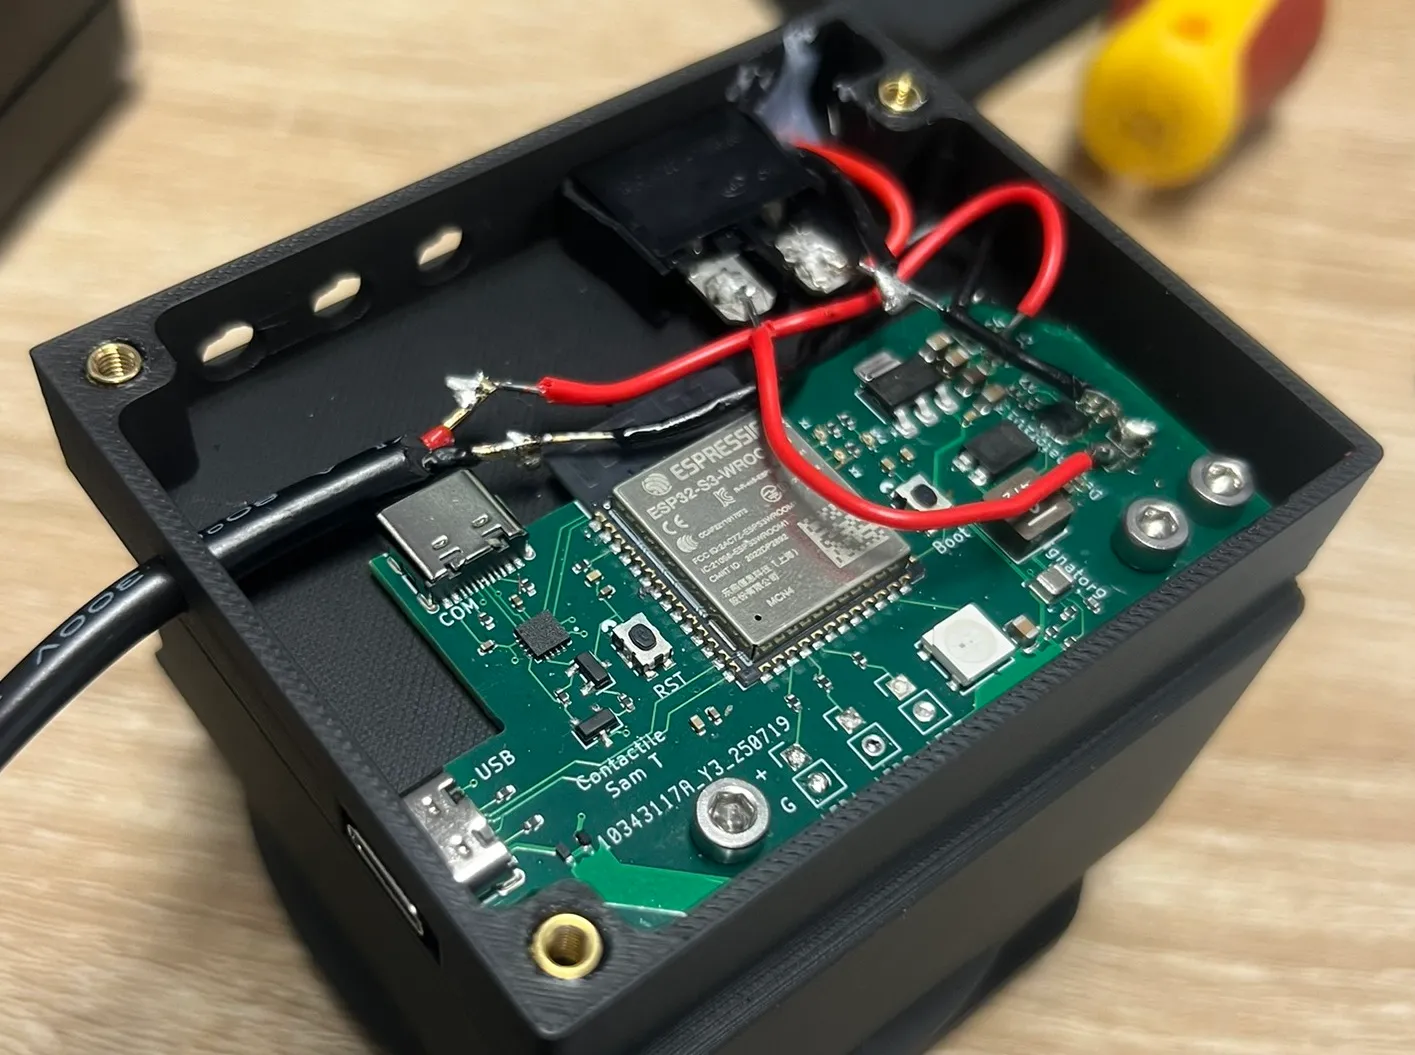
Figure: The PCB
The PCB was manufactured by JLCPCB, and the first iteration worked as expected. The MCU is an ESP32-S3 WROOM and ESP-IDF was used to program the USB and BLE peripherals.
The power supply consists of eight (high current) AA rechargeable batteries. A boost converter was designed to step up the supply voltage for the gripper, and a buck converter was used for the digital circuit.
Autodesk Fusion was used to design the mechancial housing and a Bambu 3D printer was used for manufacture.
During the project I used oscilloscopes, logic analysers, multimeters, and current probes for electrical prototyping and troubleshooting.